Humanlike robotics.
Real operational questions.
Assessing humanoid assistants for mining support, inspection and controlled industrial environments.
Start where the task is defined.
Humanlike humanoids could make familiar tools and workspaces easier to use, but appearance is not evidence of industrial capability. TIN’s proposed approach begins with controlled tasks and a clear business case: routine visual inspection, inventory support, guided checks and remote expert assistance.
A supervised pilot, not an unrestricted mine deployment.
Assess the robot’s balance, payload, battery life, perception, connectivity and ability to recover safely from faults. Heat, dust, rain, vibration and uneven ground must be tested against the intended environment. Humanlike design does not remove the need for supervision or separation from moving machinery.
What a TIN pilot scope can include.
- Task selection and comparison with simpler fixed or wheeled automation.
- Vendor capability review and demonstration coordination.
- Integration with inspection records and maintenance workflows.
- Controlled trial area, trained supervisors and safe stop procedures.
- Acceptance tests for task completion, reliability and support requirements.
Scale only when the evidence supports it.
Assess completed tasks per shift, supervision time, intervention rate, downtime and total operating cost. An effective pilot may justify extension, redesign or a decision to use a different type of automation.
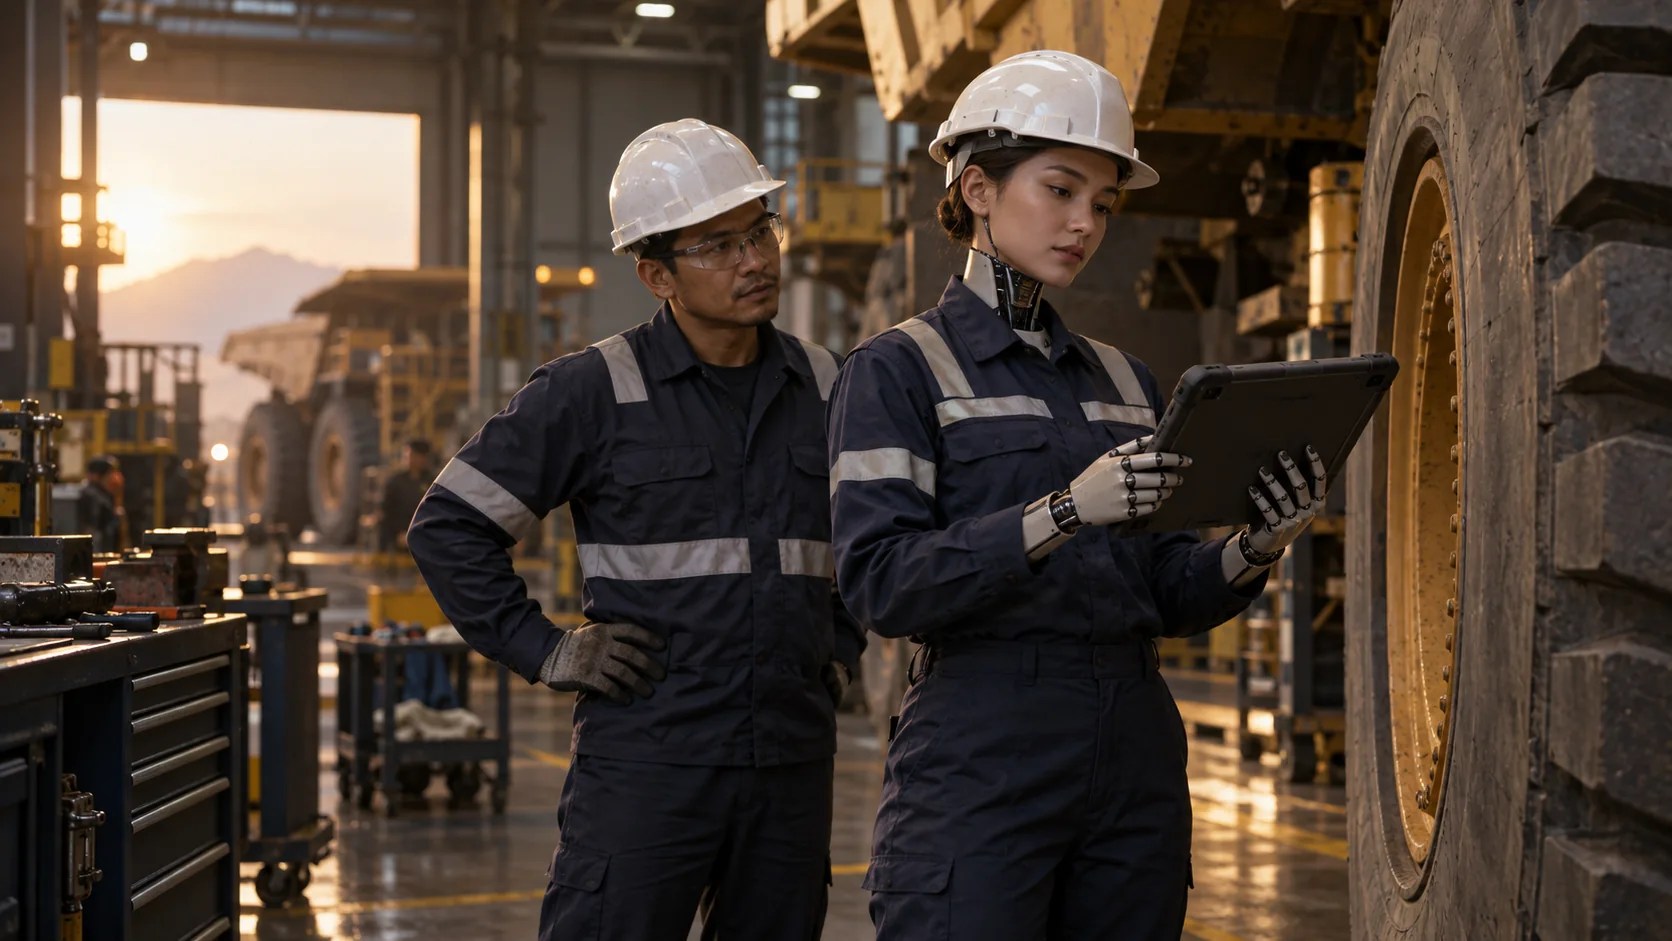
The image is an AI-generated concept showing a humanlike robotic assistant. It does not depict an existing TIN robot, customer site or completed deployment. Service availability depends on vendor capability and project assessment.

